PTC and NVIDIA Announce Onshape Integration with NVIDIA Isaac Sim
Accelerating robotics development through direct cloud-native CAD synchronization into OpenUSD-driven physical simulation environments.
Bridging CAD Kinematics and Autonomous Physical Simulation
Direct CAD-to-USD Simulation Pipeline
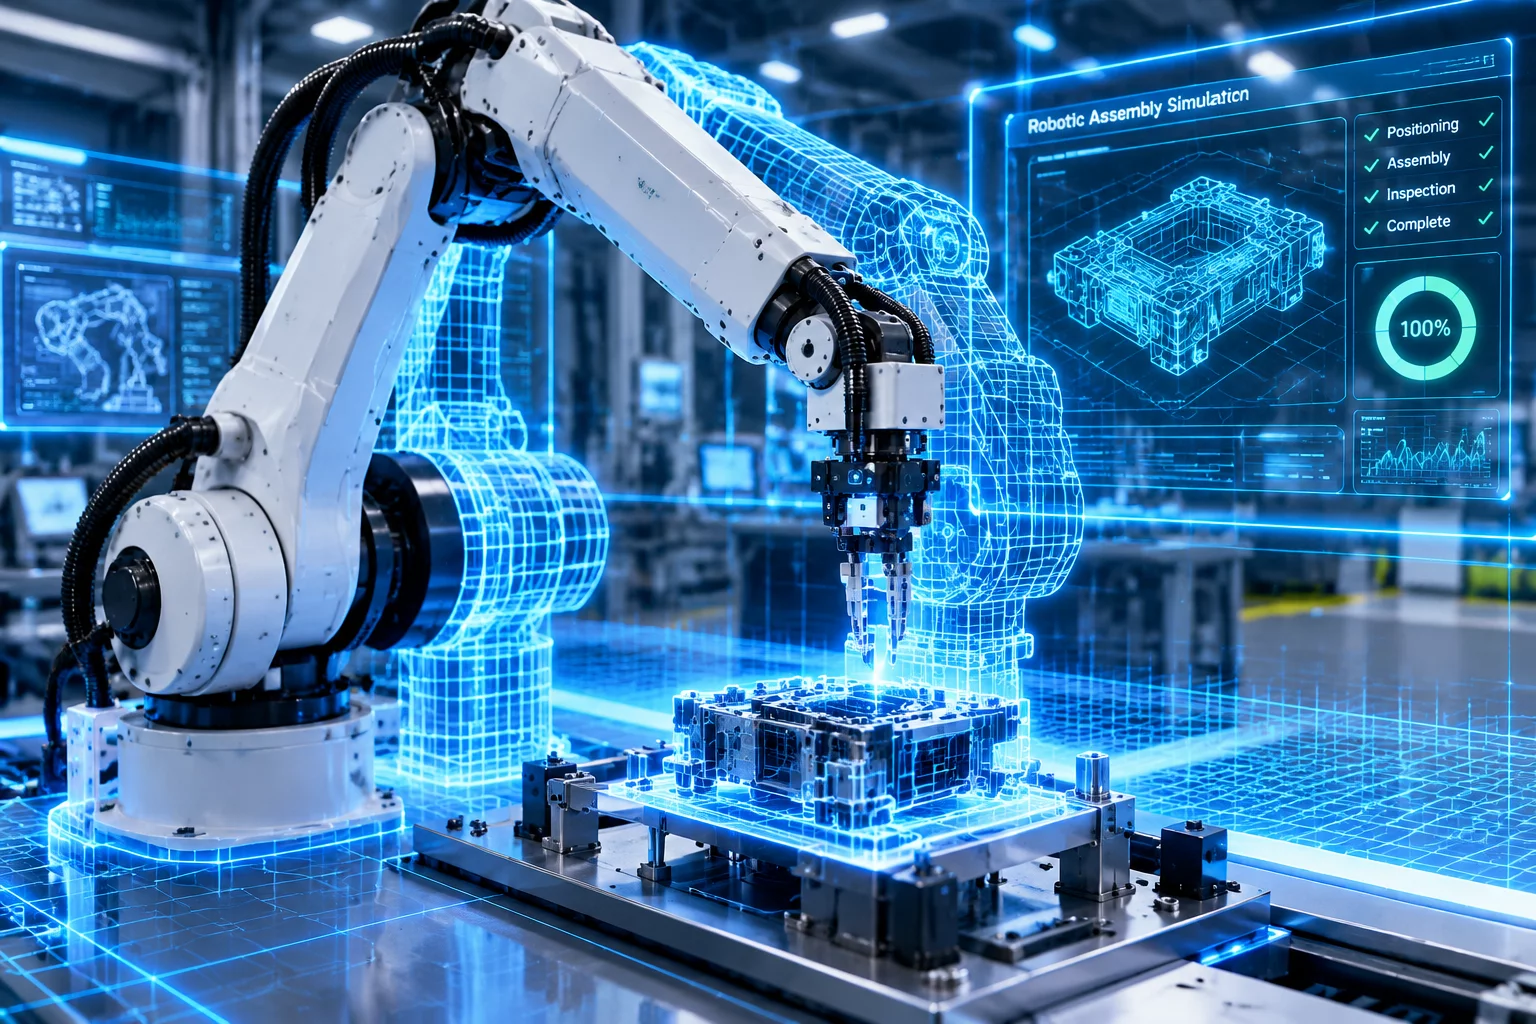
The integration allows robotics engineering teams to export mechanical assemblies directly from Onshape into NVIDIA Isaac Sim via OpenUSD formatting. Kinematic mate connectors, joint limits, inertial properties, and mass matrices transfer without manual file translation or reconstruction.
Design reviews no longer rely on static 3D models or decoupled URDF scripts. As engineers adjust joint geometry or motor placements in Onshape, autonomous simulation environments receive instant updates to test trajectory planning, synthetic sensor feeds, and physical collision boundaries.
Robotics Review Protocol
Set up isolated review windows for kinematic reach, sensor occlusion, and dynamic payload validation.
Solving the CAD-to-Simulation Disconnect in Autonomous Hardware
Developing modern autonomous robotics has traditionally suffered from a structural gap between mechanical design and software simulation. Mechanical teams model parts in high-fidelity CAD packages, while robotics software engineers build separate URDF models in simulation tools. Every mechanical revision required manual recreation of joint limits, center-of-mass coordinates, and mesh collisions.
The collaboration between PTC Onshape and NVIDIA Isaac Sim closes this gap by converting cloud-native CAD models into Universal Scene Description assets automatically. Mate connectors defined during mechanical assembly directly map into Isaac Sim revolute, prismatic, and fixed joints. Mass parameters calculated from material assignments carry over without modification, removing human error from simulation setup.
“Connecting Onshape directly to NVIDIA Isaac Sim turns CAD from a static drafting archive into an active, physically verifiable digital twin.”
— Simulation Architecture Review BoardEngineering teams can run parallel review cycles where robotic perception algorithms, reinforcement learning models, and control routines are tested against exact physical geometry weeks before physical tooling or machining begins.
Cross-Functional Review Windows for Sim-Ready Robotics
When engineering and simulation pipelines merge, the review question for each department changes. Isolated review windows prevent general opinions and ensure rigorous verification across all technical domains:
-
Mechanical Engineering Window Are all mate connectors, motion limits, and physical material densities fully configured in Onshape before triggering the Isaac Sim pipeline?
-
Robotics & Control Window Do actuator torque ratings in CAD match the dynamic payload requirements observed in Isaac Sim physics stress testing?
-
Tooling & Manufacturing Window Does simulated joint articulation create cable harness pinches, tooling access collisions, or clearance hazards during maintenance?
-
Sensor & Vision Systems Window Are LiDAR, depth camera, and IMU mounting points unobstructed across the complete range of simulated arm movements?
-
Program Management Window Has the design passed automated sim regression benchmarks prior to cutting production release revisions in Onshape?
Framing review discussions around explicit operational criteria prevents expensive hardware redesigns by confirming functional performance in simulated reality first.
Technical Integration Specifications
The technical parameters governing data exchange between Onshape and NVIDIA Isaac Sim focus on data integrity, geometry fidelity, and continuous version tracking:
| Interchange Standard | Universal Scene Description (OpenUSD) with Physics Schema extension |
|---|---|
| Kinematic Translation | Automatic mapping of Revolute, Slider, Cylindrical, and Fastened mates to Isaac Sim USD joints |
| Mass & Inertia Handling | Direct extraction from Onshape material library and computed volumetric moments |
| Version Control Traceability | Direct link back to Onshape immutable branch IDs and release micro-versions |
Request Review Case Consultation
Structure your internal engineering reviews with isolated perspectives and tailored inquiry protocols.